Loading...
Searching...
No Matches
Object3dRender Class Reference
#include <Graph.hh>
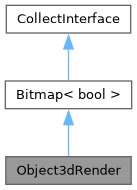
Inheritance diagram for Object3dRender:
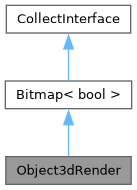
Collaboration diagram for Object3dRender:
Public Member Functions | |
| Object3dRender (VolumeObject &o, int sx, int sy, Point p, float min_z, float max_z) | |
| void | Prepare () |
| int | SizeX () const |
| int | SizeY () const |
| bool | Map (int x, int y) const |
| Point2d | projection (Point p) const |
| void | render (Point p, float startz) |
| Public Member Functions inherited from Bitmap< bool > | |
| virtual bool | ReadyToPrepare () const |
| virtual | ~Bitmap () |
| virtual bool | IsDirectGltfImage () const |
| virtual bool | HasBatchMap () const |
| virtual BufferRef | BatchMap (int start_x, int end_x, int start_y, int end_y) const |
| Public Member Functions inherited from CollectInterface | |
| virtual | ~CollectInterface () |
| virtual void | Collect (CollectVisitor &vis)=0 |
| virtual int | NumBlocks () const |
| virtual void | HeavyPrepare ()=0 |
| virtual void | FirstFrame () |
Constructor & Destructor Documentation
◆ Object3dRender()
|
inline |
Member Function Documentation
◆ Map()
|
inlinevirtual |
Implements Bitmap< bool >.
◆ Prepare()
|
inlinevirtual |
Implements Bitmap< bool >.
◆ projection()
Here is the caller graph for this function:

◆ render()
|
inline |
◆ SizeX()
|
inlinevirtual |
Implements Bitmap< bool >.
◆ SizeY()
|
inlinevirtual |
Implements Bitmap< bool >.
The documentation for this class was generated from the following file:
